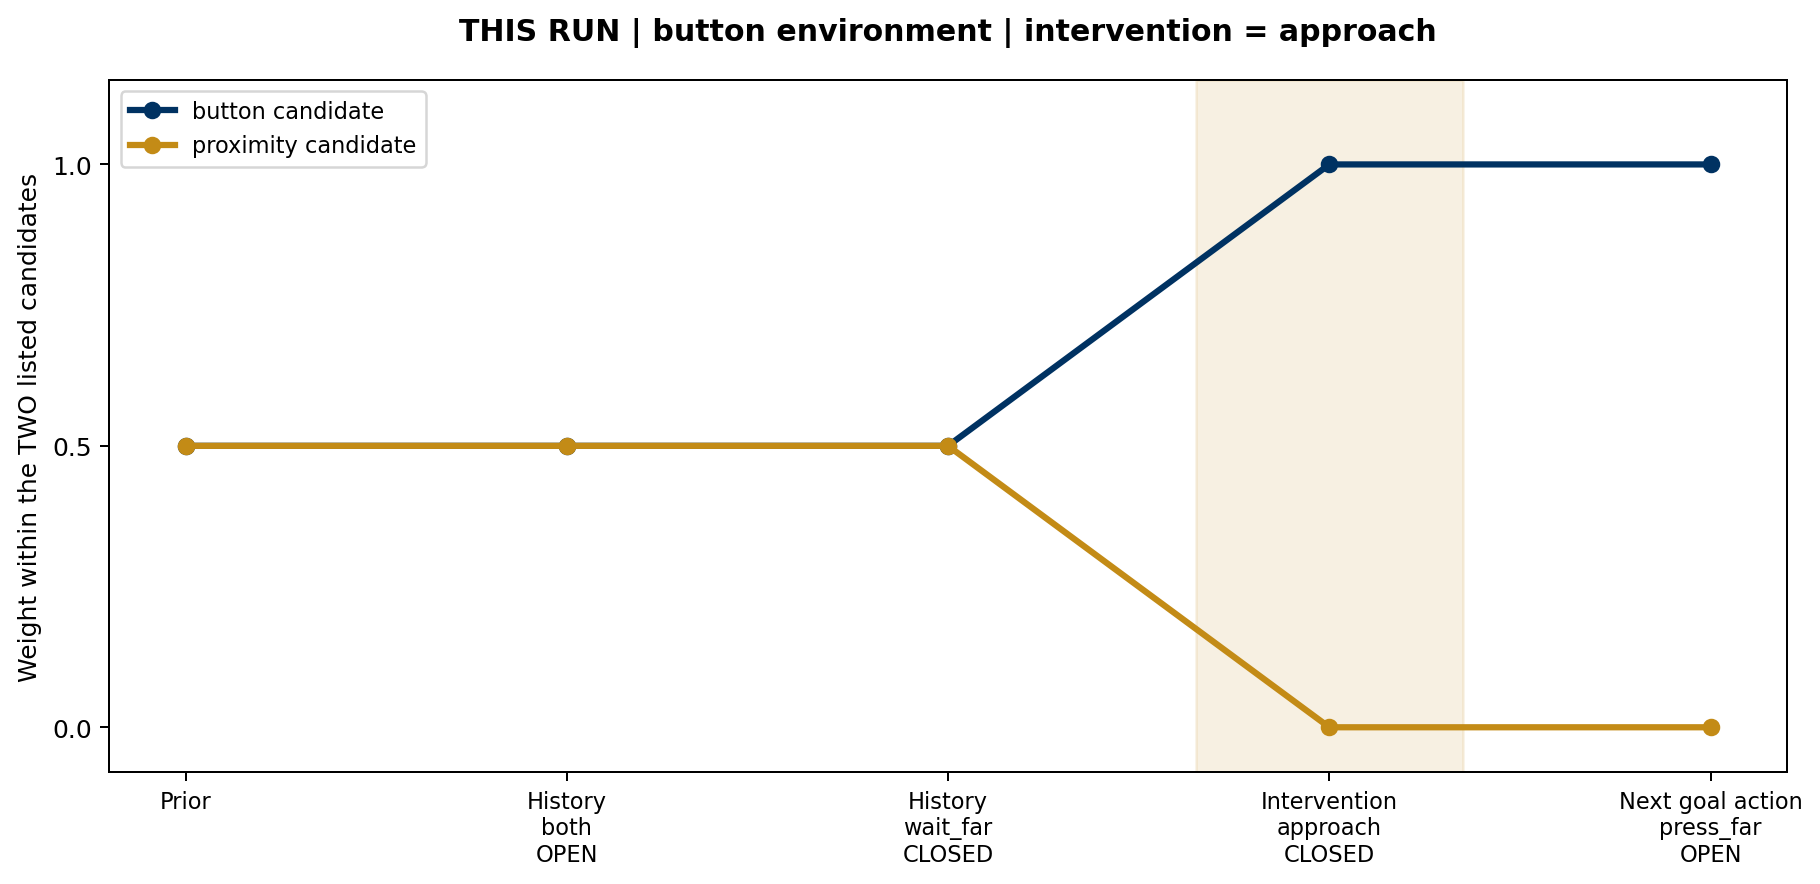
本次运行 button__approach__20261001T025630.481808Z__396147cc:固定规则环境 button、历史 ['both', 'wait_far']、先验 {'button': 0.5, 'proximity': 0.5} 与成本 {'both': 2.2, 'press_far': 1.0, 'approach': 1.2, 'wait_far': 0.0};本轮选择的干预是 approach。与同条件另一轮比较时只改 INTERVENTION。
| 阶段 | 实际动作 | 按钮预测 | 接近预测 | 实际返回 | 更新后权重(按钮 / 接近) |
|---|---|---|---|---|---|
| shared_history | both | 开 | 开 | near / 开 | 0.5 / 0.5 |
| shared_history | wait_far | 关 | 关 | far / 关 | 0.5 / 0.5 |
| intervention | approach | 关 | 开 | near / 关 | 1 / 0 |
| next_goal_action | press_far | 开 | 关 | far / 开 | 1 / 0 |
本次干预返回关门,候选熵减少 1 bit;下一动作是 press_far,独立环境实际返回开门。完成开门目标与取得区分信息分别检查。
完整记录 record.json · 图表说明 result.md
{
  "identity": {
    "run_id": "button__approach__20261001T025630.481808Z__396147cc",
    "generated_at_utc": "20261001T025630.481808Z",
    "kind": "actual_independent_rule_environment_execution",
    "truth_selected_by_experimenter": "button",
    "intervention": "approach",
    "shared_history": [
      "both",
      "wait_far"
    ],
    "prior": {
      "button": 0.5,
      "proximity": 0.5
    },
    "action_costs": {
      "both": 2.2,
      "press_far": 1.0,
      "approach": 1.2,
      "wait_far": 0.0
    },
    "trained_parameters": 0,
    "implementation": "Lecture04-v20-LAB10"
  },
  "records": [
    {
      "phase": "shared_history",
      "action": "both",
      "predictions": {
        "button": true,
        "proximity": true
      },
      "observation": {
        "position": "near",
        "door_open": true
      },
      "belief_before": {
        "button": 0.5,
        "proximity": 0.5
      },
      "belief_after": {
        "button": 0.5,
        "proximity": 0.5
      },
      "entropy_before_bits": 1.0,
      "entropy_after_bits": 1.0
    },
    {
      "phase": "shared_history",
      "action": "wait_far",
      "predictions": {
        "button": false,
        "proximity": false
      },
      "observation": {
        "position": "far",
        "door_open": false
      },
      "belief_before": {
        "button": 0.5,
        "proximity": 0.5
      },
      "belief_after": {
        "button": 0.5,
        "proximity": 0.5
      },
      "entropy_before_bits": 1.0,
      "entropy_after_bits": 1.0
    },
    {
      "phase": "intervention",
      "action": "approach",
      "predictions": {
        "button": false,
        "proximity": true
      },
      "observation": {
        "position": "near",
        "door_open": false
      },
      "belief_before": {
        "button": 0.5,
        "proximity": 0.5
      },
      "belief_after": {
        "button": 1.0,
        "proximity": 0.0
      },
      "entropy_before_bits": 1.0,
      "entropy_after_bits": -0.0
    },
    {
      "phase": "next_goal_action",
      "action": "press_far",
      "predictions": {
        "button": true,
        "proximity": false
      },
      "observation": {
        "position": "far",
        "door_open": true
      },
      "belief_before": {
        "button": 1.0,
        "proximity": 0.0
      },
      "belief_after": {
        "button": 1.0,
        "proximity": 0.0
      },
      "entropy_before_bits": -0.0,
      "entropy_after_bits": -0.0
    }
  ],
  "candidate_information_bits": {
    "both": 0.0,
    "press_far": 1.0,
    "approach": 1.0,
    "wait_far": 0.0
  },
  "final_belief": {
    "button": 1.0,
    "proximity": 0.0
  },
  "next_action": "press_far",
  "goal_open_succeeded": true
}